
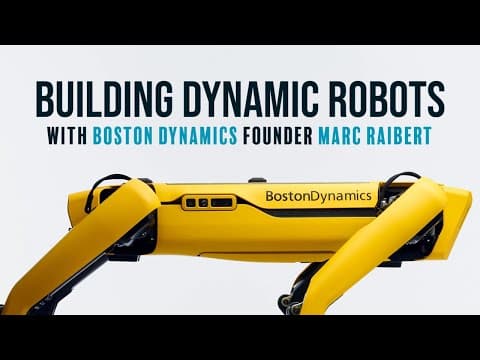
Building Dynamic Legged Robots
Traces four decades of dynamic balance, spring-loaded inverted pendulum mechanics, hydraulic/electric actuation, and whole-body control from one-legged hoppers to Atlas and Spot.
Faculty & visiting speakers
Self-contained seminars, public lectures, and invited talks.
Traces four decades of dynamic balance, spring-loaded inverted pendulum mechanics, hydraulic/electric actuation, and whole-body control from one-legged hoppers to Atlas and Spot.