Lecture 1.1: Introduction to Distributed Systems (CST-DS)
14:36Distributed Systems 1.3: RPC (Remote Procedure Call)
19:44Distributed Systems 2.3: System models
20:44Distributed Systems 3.1: Physical time
20:47Distributed Systems 3.2: Clock synchronisation
15:57Distributed Systems 3.3: Causality and happens-before
16:24Distributed Systems 4.1: Logical time
24:01Lecture 4.2: Broadcast Ordering (CST-DS)
16:19Lecture 5.1: Replication (CST-DS)
25:21Lecture 6.1: Consensus (CST-DS)
18:15Lecture 6.2: Raft (CST-DS)
38:09Lecture 7.1: Two-Phase Commit (CST-DS)
18:45Lecture 7.2: Linearizability (CST-DS)
18:44Lecture 7.3: Eventual Consistency (CST-DS)
14:59Lecture 8.1: Collaboration Software (CST-DS)
36:26Distributed Systems 3.1: Physical time

Associate Professor of Distributed Systems
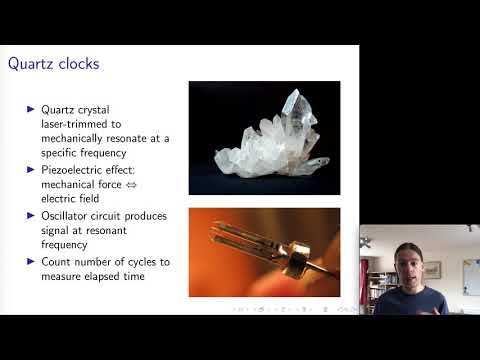
This lecture segment introduces the complexities of physical time in distributed systems, detailing issues such as clock drift, the inherent inaccuracies of hardware clocks, and the mechanisms of Network Time Protocol (NTP) for synchronization across nodes.
Accompanying lecture notes: https://www.cl.cam.ac.uk/teaching/2122/ConcDisSys/dist-sys-notes.pdf
Full lecture series: https://www.youtube.com/playlist?list=PLeKd45zvjcDFUEv_ohr_HdUFe97RItdiB
This video is part of an 8-lecture series on distributed systems, given as part of the undergraduate computer science course at the University of Cambridge. It is preceded by an 8-lecture course on concurrent systems for which videos are not publicly available, but slides can be found on the course web page: https://www.cl.cam.ac.uk/teaching/2122/ConcDisSys/materials.html
Distributed Systems 2.3: System models
Next · Lecture 5Distributed Systems 3.2: Clock synchronisation
Seminar notes & discussion
No public seminar notes on this lecture yet.