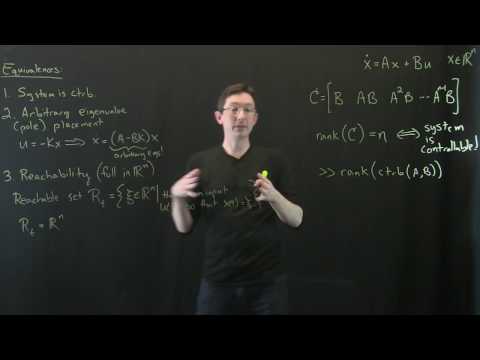
Opening Controllability, Reachability, and Eigenvalue Placement
Controllability, Reachability, and Eigenvalue Placement
- Length
- 11 min
- Level
- Undergraduate
- Recorded
- University of Washington2017
Opening Controllability, Reachability, and Eigenvalue Placement
Chapter 1 of 3: Controllability matrix and rank condition
Controllability of a linear system is decided by the rank of the controllability matrix, built from and successive powers of . Brunton states that the system is controllable exactly when this matrix has rank , the state dimension. Controllability then proves equivalent to arbitrary placement of closed-loop eigenvalues through state feedback gains, and to reachability of any vector in . A geometric argument from linearity shows that reaching the unit sphere suffices, since scaling the input reaches any distance. Session 6 of the Control Bootcamp follows Chapter 8 of Brunton and Kutz and assumes matrix rank and eigenvalues.

Your comment is kept while you sign up.Sign in
Links the rank of the controllability matrix to pole placement and to reaching every state in .
Controllability of a linear system is decided by the rank of the controllability matrix, built from and successive powers of . Brunton states that the system is controllable exactly when this matrix has rank , the state dimension. Controllability then proves equivalent to arbitrary placement of closed-loop eigenvalues through state feedback gains, and to reachability of any vector in . A geometric argument from linearity shows that reaching the unit sphere suffices, since scaling the input reaches any distance. Session 6 of the Control Bootcamp follows Chapter 8 of Brunton and Kutz and assumes matrix rank and eigenvalues.
This lecture
Lecture 6 of 28 of Control Bootcamp: Linear Systems & Optimal Control.
Choose a node to see how it connects to this lecture. What comes before is on the leftat the top. What comes after is on the rightat the bottom. The ring is what it teaches. People and places are above. Other lectures and books are below.
Press a chosen node again to open it.


