Linear Dynamics, Optimal Control & Underactuated Robotics
Matrix exponentials, stability eigenvalues, feedback regulators, and nonlinear locomotion
Progresses from Stanford EE263 linear dynamical systems and UW state-space control into MIT 6.832 nonlinear phase-portrait control for agile robots.
Curriculum sequence
6
Lecture 1 | Introduction to Linear Dynamical Systems
Frames continuous and discrete linear dynamical models across circuits, mechanics, and estimation.
Lecture 2 | Introduction to Linear Dynamical Systems
Links linear input-output operators to impulse responses and state propagation.
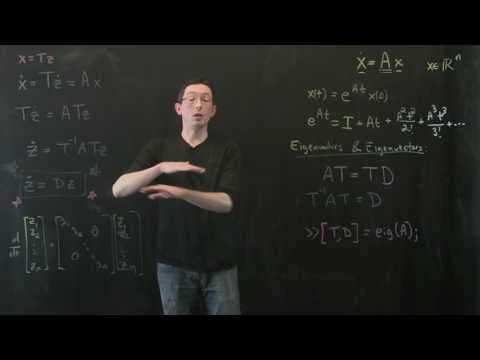

Linear Systems [Control Bootcamp]
Derives canonical state-space ODEs and linearization around operating equilibria.
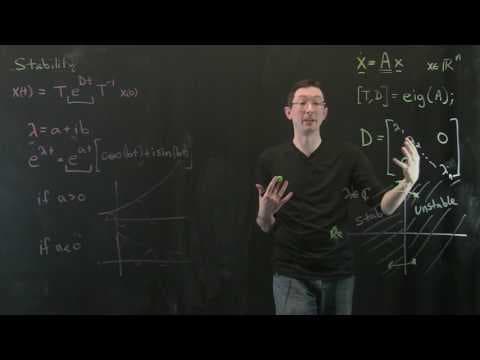
Stability and Eigenvalues [Control Bootcamp]
Characterizes asymptotic stability through complex-plane eigenvalue geometry.
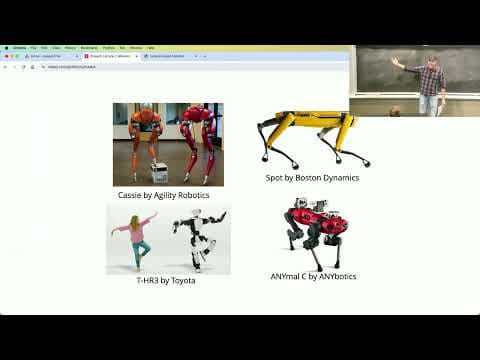

Robot Dynamics and Model-Based Control (MIT 6.8210, Lecture 1)
Introduces underactuated mechanical systems where actuators are fewer than degrees of freedom.
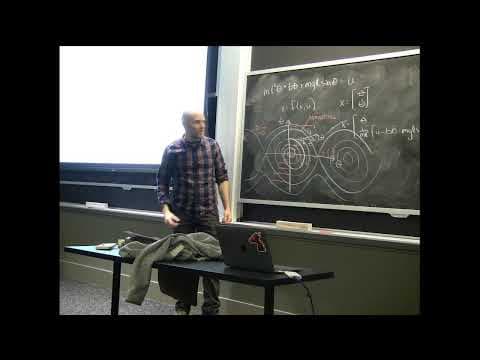
Spring 2023 6.8210 Lecture 2: Nonlinear Dynamics
Uses nonlinear phase portraits and energy shaping to swing up and stabilize pendula.