Control Bootcamp: Overview
19:31Linear Systems [Control Bootcamp]
24:47Stability and Eigenvalues [Control Bootcamp]
19:30Linearizing Around a Fixed Point [Control Bootcamp]
30:46Controllability [Control Bootcamp]
32:29Degrees of Controllability and Gramians [Control Bootcamp]
15:24Lecture: Inverted Pendulum on a Cart (ME 564)
15:08Lecture: Kalman Filter Example (ME 564)
22:12Lecture: Inverted Pendulum on a Cart (ME 564)

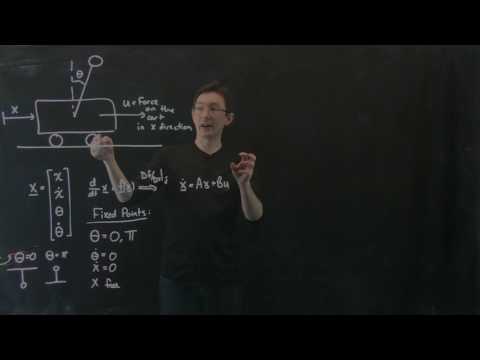
This lecture introduces the inverted pendulum on a cart as a control system example. It covers state-space representation, fixed point analysis, and Matlab simulation, laying the groundwork for feedback control design.
In this video, we introduce an example system to control: an inverted pendulum on a cart. We describe the state-space, find the fixed points, and simulate the system in Matlab. Because the linearized system is controllable, we will be able to arbitrarily place the eigenvalues of the closed-loop system through feedback in the next two videos.
These lectures follow Chapter 8 from:
"Data-Driven Science and Engineering: Machine Learning, Dynamical Systems, and Control" by Brunton and Kutz
Degrees of Controllability and Gramians [Control Bootcamp]
Next · Lecture 8Lecture: Kalman Filter Example (ME 564)