Control Bootcamp: Linear Systems & Optimal Control
State-space dynamical systems, stability eigenvalues, controllability, observability, Linear Quadratic Regulators (LQR), and Kalman filtering derived for modern control engineering.
Professor of Mechanical Engineering, University of Washington
Complete university lecture series taught by Steve Brunton.
State-space dynamical systems, stability eigenvalues, controllability, observability, Linear Quadratic Regulators (LQR), and Kalman filtering derived for modern control engineering.
Self-contained public lectures, keynote addresses, and research seminars.
Shows how lifting finite-dimensional nonlinear ODEs into infinite-dimensional observable spaces enables spectral decomposition and linear optimal control.
High-density applied math lecture connecting X = UΣV* directly to scientific computing, reduced-order modeling, and high-dimensional data compression.
An introductory overview of optimization, detailing its core concepts, diverse applications across machine learning and control, and the foundational structure for advanced study.
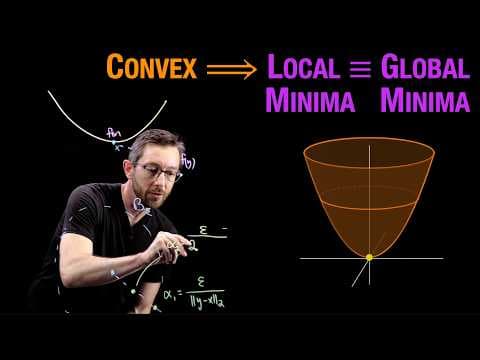
Dissecting the fundamental components of an optimization problem, exploring objective functions, constraints, and the implications of convexity on problem categories.
Professor Steve Brunton proves the convexity of all norms, discussing its fundamental implications for optimization theory and machine learning algorithms.
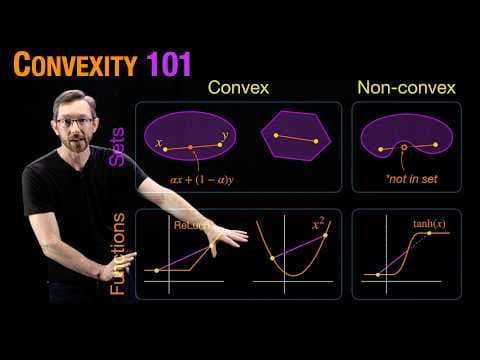
An explicit definition and exploration of convex functions, examining their fundamental properties, diverse examples, and implications for optimization problems.
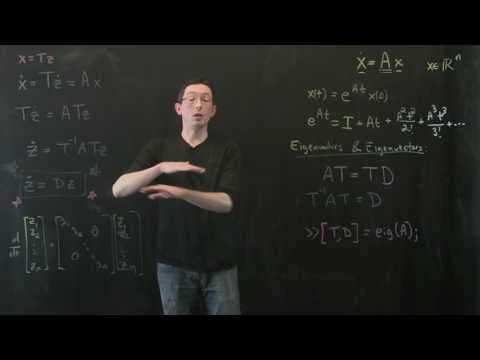
Matrix exponentials, stability eigenvalues, feedback regulators, and nonlinear locomotion
Stanford University · University of Washington · MIT
Search or browse every recorded session across courses and talks.